Spur Gear Motor GM37BM545
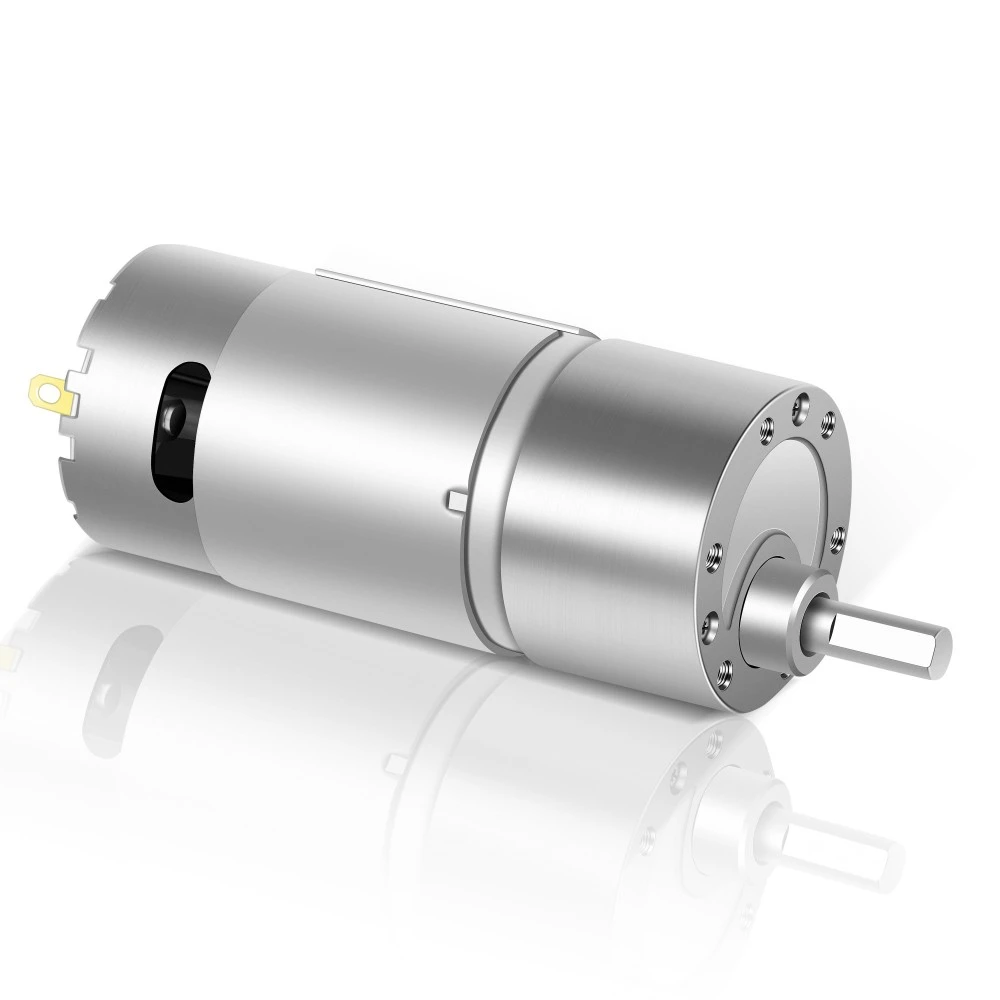
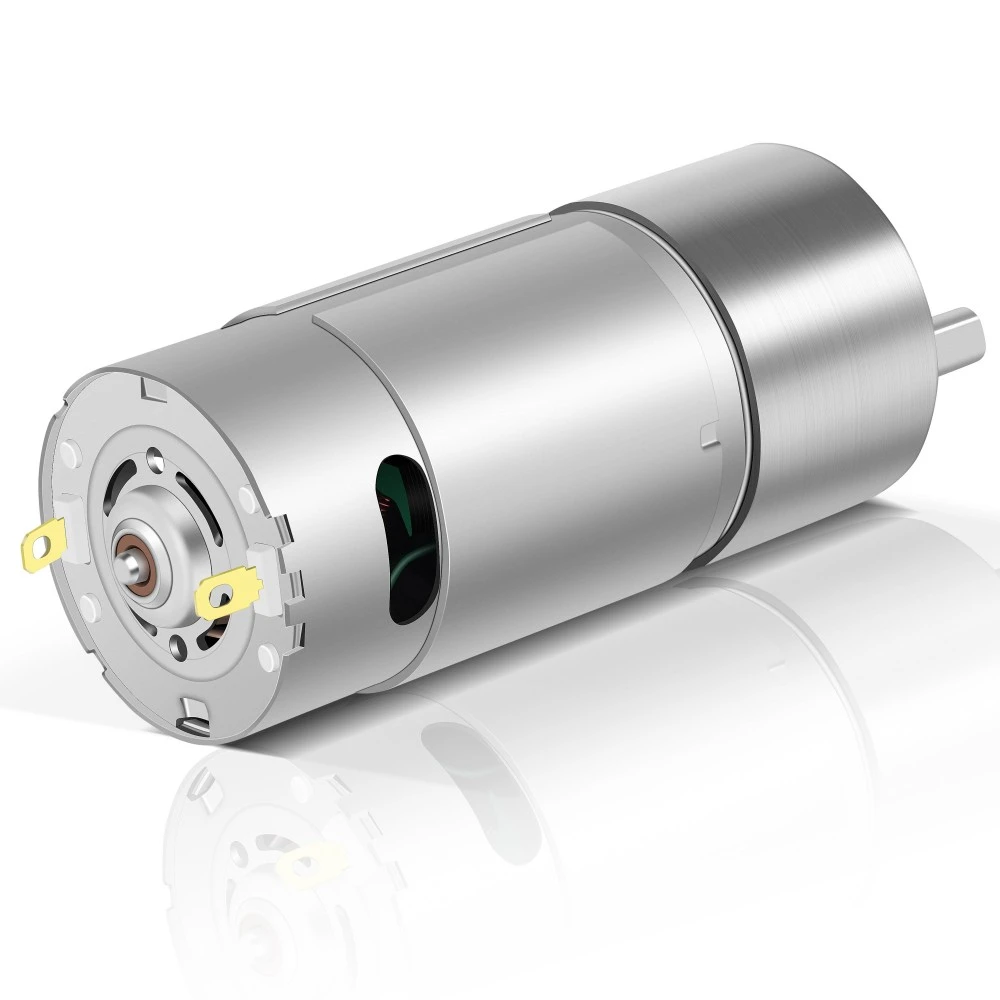
The GM37BM545 / GM37BM555 / GM37BM575 Series is a 37 mm-class DC spur gear motor platform designed for compact OEM mechanisms that require stable speed reduction and higher output torque. The supplied reference configurations cover 12 VDC and 24 VDC operation, rated speeds from 17.5 to 210 RPM, and rated torque from 0.85 to 2.0 N·m. Reference ratios are 1:44, 1:113, and 1:170 based on the corresponding model suffixes. This high-torque DC gear motor is suitable for industrial automation, smart equipment, commercial devices, compact actuators, and other small electromechanical transmission systems where package size, torque, current, and duty cycle must be balanced.
Product Overview
The GM37BM545 / GM37BM555 / GM37BM575 Series is a 37 mm-class DC spur gear motor platform designed for compact OEM mechanisms that require stable speed reduction and higher output torque. The supplied reference configurations cover 12 VDC and 24 VDC operation, rated speeds from 17.5 to 210 RPM, and rated torque from 0.85 to 2.0 N·m. Reference ratios are 1:44, 1:113, and 1:170 based on the corresponding model suffixes. This high-torque DC gear motor is suitable for industrial automation, smart equipment, commercial devices, compact actuators, and other small electromechanical transmission systems where package size, torque, current, and duty cycle must be balanced.
Model Information
| Reference Model | Motor | Ratio | Rated Voltage | Product Category |
| GM37BM545-44K | SL-545 | 1:44* | 24 VDC | DC Spur Gear Motor |
| GM37BM555-113K | SL-555 | 1:113* | 24 VDC | DC Spur Gear Motor |
| GM37BM575-170K | SL-575 | 1:170* | 12 VDC | DC Spur Gear Motor |
Reference Gearmotor Performance
| Gearmotor Model | Ratio | Rated Voltage (V) | No-Load Speed (RPM) | No-Load Current (mA) | Rated Speed (RPM) | Rated Current (mA) | Rated Torque N·m / kgf·cm | Stall Current (mA) | Stall Torque N·m / kgf·cm |
| GM37BM545-44K | 1:44* | 24 VDC | 240 | ≤450 | 210 | ≤2200 | 0.85 / 8.5 | ≤15000 | 4.5 / 45 |
| GM37BM555-113K | 1:113* | 24 VDC | 60 | ≤250 | 52.5 | ≤1250 | 1.8 / 18 | ≤8500 | 6.0 / 60 |
| GM37BM575-170K | 1:170* | 12 VDC | 20 | ≤250 | 17.5 | ≤1200 | 2.0 / 20 | ≤7500 | 8.0 / 80 |
Gearbox Technical Data
The supplied technical data provides three GM37BM reference gearmotor configurations: GM37BM545-44K, GM37BM555-113K, and GM37BM575-170K. Separate stage-count and gearbox-efficiency data were not included in the supplied workbook, so no unverified stage or efficiency values are introduced in this detail page.
| Item | Reference |
| Gearbox Diameter | Ø37 mm |
| Gearbox Length A | Per drawing |
| PMDC Motor Diameter | Per drawing |
| Output Shaft | Per drawing |
| Mounting Interface | Per drawing |
PMDC Motor Technical Data
| PMDC Motor Model | Motor Length B (mm) | Rated Voltage (V) | No-Load Speed (RPM) | No-Load Current (mA) | Rated Speed (RPM) | Rated Current (mA) | Rated Torque mN·m / gf·cm | Stall Current (mA) | Stall Torque mN·m / gf·cm |
| SL-545 (source ref. 240160) | —* | 24 VDC | 10600 | ≤320 | 9300 | ≤2100 | 32 / 320 | ≤14500 | 250 / 2500 |
| SL-555 (source ref. 246800) | —* | 24 VDC | 6800 | ≤150 | 6000 | ≤1100 | 28 / 280 | ≤8000 | 240 / 2400 |
| SL-575 (source ref. 123500) | —* | 12 VDC | 3500 | ≤65 | 3050 | ≤950 | 26.5 / 265 | ≤7200 | 210 / 2100 |
Mechanical & Interface Reference
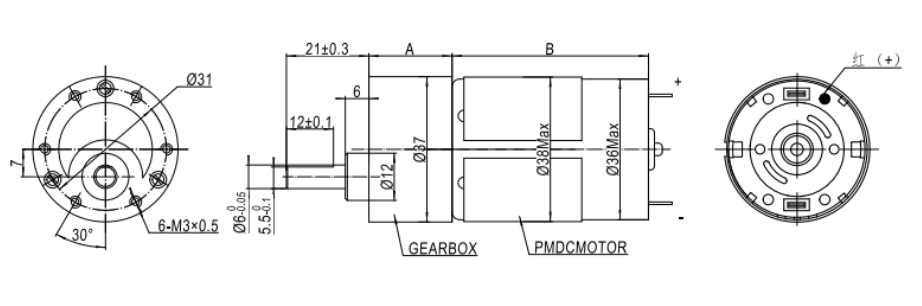
The supplied mechanical drawing shows a Ø37 mm gearbox matched to PMDC motors with Ø38 mm Max and Ø36 mm Max envelope references. The output shaft is Ø6 mm with a D-flat, with a 12 ±0.1 mm shaft projection from the front reference. The front mounting interface uses six M3×0.5 threaded holes on a Ø31 mm mounting circle. Gearbox length is defined by dimension A and motor length by dimension B; final A/B dimensions must be confirmed for the selected motor and gearbox configuration.
Main Applications
Smart Agriculture & Gardening
Electric pruning tools, automatic feeding equipment, small irrigation devices, spraying equipment, quantitative feeding, rotary adjustment and automatic opening/closing mechanisms.
Focus: Evaluate dust/moisture exposure, startup resistance, jam conditions, gear material, lubrication and product-level sealing in the real equipment.
Automotive Electronics
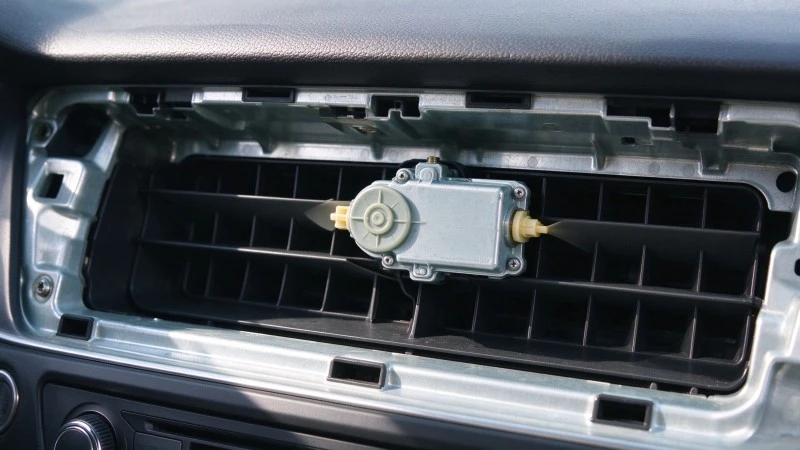
Automotive door locks, charging-port covers, HVAC air flaps, hidden door handles and other small opening/closing mechanisms.
Focus: Validate high/low-temperature start, vibration, stall, noise, duty cycle and batch consistency according to the customer project standard.
Smart Home
Smart door locks, electric curtains, window openers, smart blinds, automatic soap dispensers, smart bins and compact appliance actuators.
Focus: Balance noise, power consumption, startup current, speed, torque, package size and repeated-cycle reliability.
Medical Equipment
Electronic blood pressure monitors, drug-dispensing equipment, sample transport mechanisms, medical valves and compact rotate/push-pull/open-close/quantitative actuators.
Focus: Evaluate noise, vibration, temperature rise, duty cycle, stall protection and batch consistency inside the actual device.
AI Robots
Service-robot grippers, hatches, feeding mechanisms, cleaning modules and light-load joints.
Focus: For frequent start-stop or reversing, verify gear impact, wear, backlash, lubrication, output-shaft loading and cycle life.
Industrial Automation
Small conveyors, feeders, sorting mechanisms, labeling equipment, automatic fixtures and inspection equipment.
Focus: Separate continuous, starting and peak torque requirements; match motor, ratio and stage count to the actual cycle rather than applying one generic safety factor.
Commercial / Office Equipment
Coffee machines, printers, copiers, smart lockers and ticketing equipment for feeding, dispensing, opening/closing, locking and transmission.
Focus: Evaluate jam/stall peak torque, noise, cycle life and recovery logic while controlling package size and cost.
Custom Drive Applications
Non-standard small transmission mechanisms where standard voltage, speed, ratio, shaft, mounting or motor configuration does not fit.
Focus: Re-match motor, ratio, stage count, output shaft and operating point to the customer mechanism and validation target.
Customization Range
Gear Ratio & Stage Count
Select the appropriate reference ratio and motor configuration against target speed, torque, current, noise, life, and package requirements. The supplied reference ratios are 1:44, 1:113, and 1:170; other ratios require engineering confirmation.
Motor Configuration
Motor parameters can be evaluated around the supplied SL-545, SL-555, and SL-575 PMDC motor references. Project-specific voltage, operating point, and matching requirements should be confirmed through engineering evaluation and sample validation.
Output Shaft
Output-shaft and mechanical-interface customization can be evaluated from the customer interface drawing. Provide shaft geometry, length, flat/thread feature, tolerance, radial/axial load, and mating-interface requirements.
Performance Matching
Output speed, torque and current should be matched to the actual continuous/start/peak load and duty cycle. A target RPM alone is insufficient for reliable selection.
Gear / Lubrication Optimization
For noise, life, start-stop or environmental requirements, gear material, meshing condition and lubrication can be evaluated as part of the project solution.
Wiring / Interface
Lead wire and terminal/interface requirements can be evaluated from drawings, samples and assembly constraints.
Validation & Mass Production
Sample-stage validation can cover speed, current, torque, noise, temperature rise, stall/jam behavior, cycle life and installation fit; pilot production should confirm process capability and batch consistency.
FAQ
Q1. What applications are spur gear motors best suited for?
Spur gear motors are well suited for small drive systems with relatively stable loads where efficiency, cost, simple structure, and reliable mass production are important. Typical applications include feeders, small conveyors, opening and closing mechanisms, dispensing systems, smart home devices, medical equipment, industrial automation, and commercial equipment.
Q2. How do I select the right spur gear motor for my application?
Motor selection should be based on the operating voltage, target output speed, continuous torque, starting torque, peak torque, gear ratio, installation space, duty cycle, and operating environment. For applications with jamming, frequent start-stop, or reversing, the actual load profile should also be evaluated rather than selecting the motor based only on no-load speed or equipment weight.
Q3. How can noise and vibration be reduced in a spur gear motor?
Noise and vibration can be reduced by optimizing motor speed, gear accuracy, gear material, backlash, lubrication, assembly tolerances, and mounting structure. Because the final enclosure can amplify resonance, low-noise performance should be validated in the complete customer mechanism rather than relying only on motor no-load noise.
Q4. How should stall, overload, and frequent start-stop conditions be evaluated?
Continuous torque, starting torque, peak torque, stall current, and operating time should be evaluated separately. For applications that may jam or overload, current detection, operation timeout, reverse recovery, or mechanical protection can help reduce the risk of overheating and gear damage. Frequent start-stop and reversing applications should also be validated for gear wear, backlash, temperature rise, and service life.
Q5: How do I place an order with Shunli Motor?
Please send us your application requirements or motor specifications. Our engineering team will develop a suitable solution, confirm the technical details, and provide samples for evaluation. Once the samples are approved, we will arrange mass production. Shipping methods can be selected based on your delivery requirements.
Product Categories
Enable Customized Solutions to Be Implemented Faster
Whether you're in the product concept, prototype development, or mass production phase, Shunli Motors can help you find the right micro geared motor drive solution based on your specific application needs.
Submit your product requirements now and get selection advice from our engineers.
Related Products
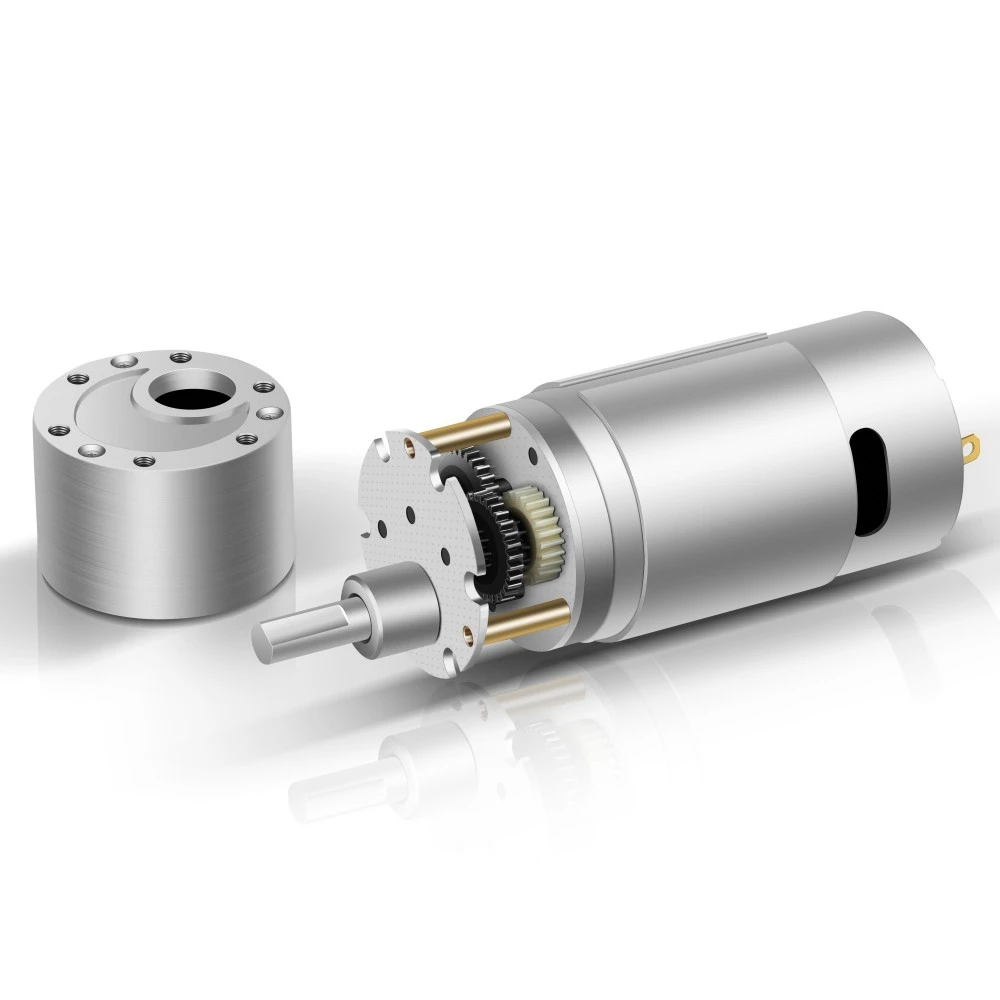
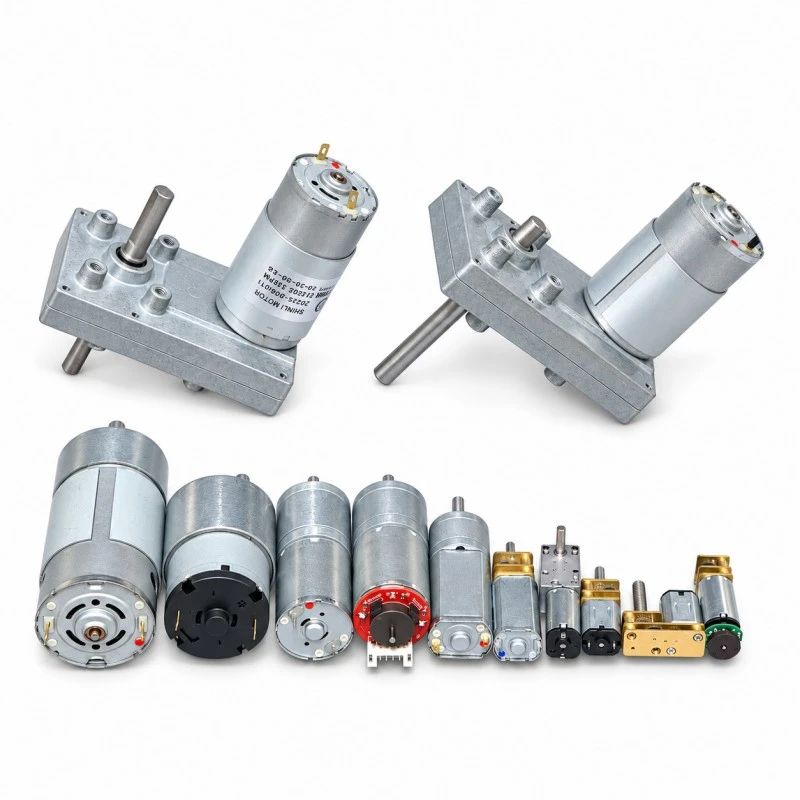
The Spur Gear Motor combines a DC motor with a multi-stage spur gearbox to provide a mature, efficient, and cost-effective drive solution for compact transmission mechanisms. Its simple gear structure supports flexible ratio, shaft, and mounting customization, making it suitable for smart home devices, commercial equipment, automotive actuators, smart landscaping systems, and industrial automation. It is a practical choice for projects that need a balance of output speed, torque, reliability, manufacturability, and cost.
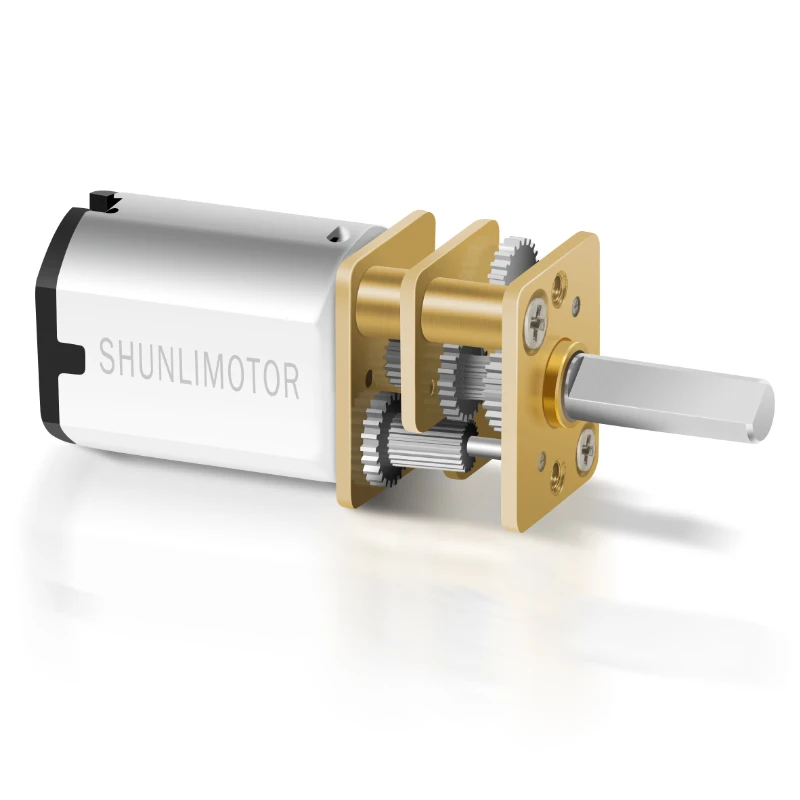
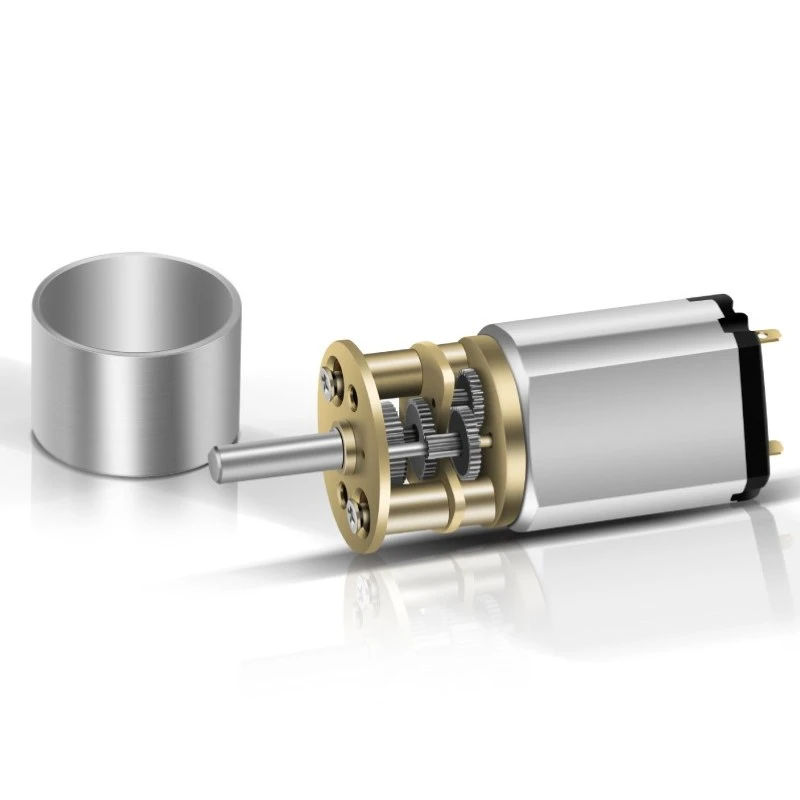
The GM12 Series is a compact 12 mm-class DC spur gear motor platform developed for miniature mechanisms that require efficient speed reduction, controlled output, and cost-effective integration in limited space.
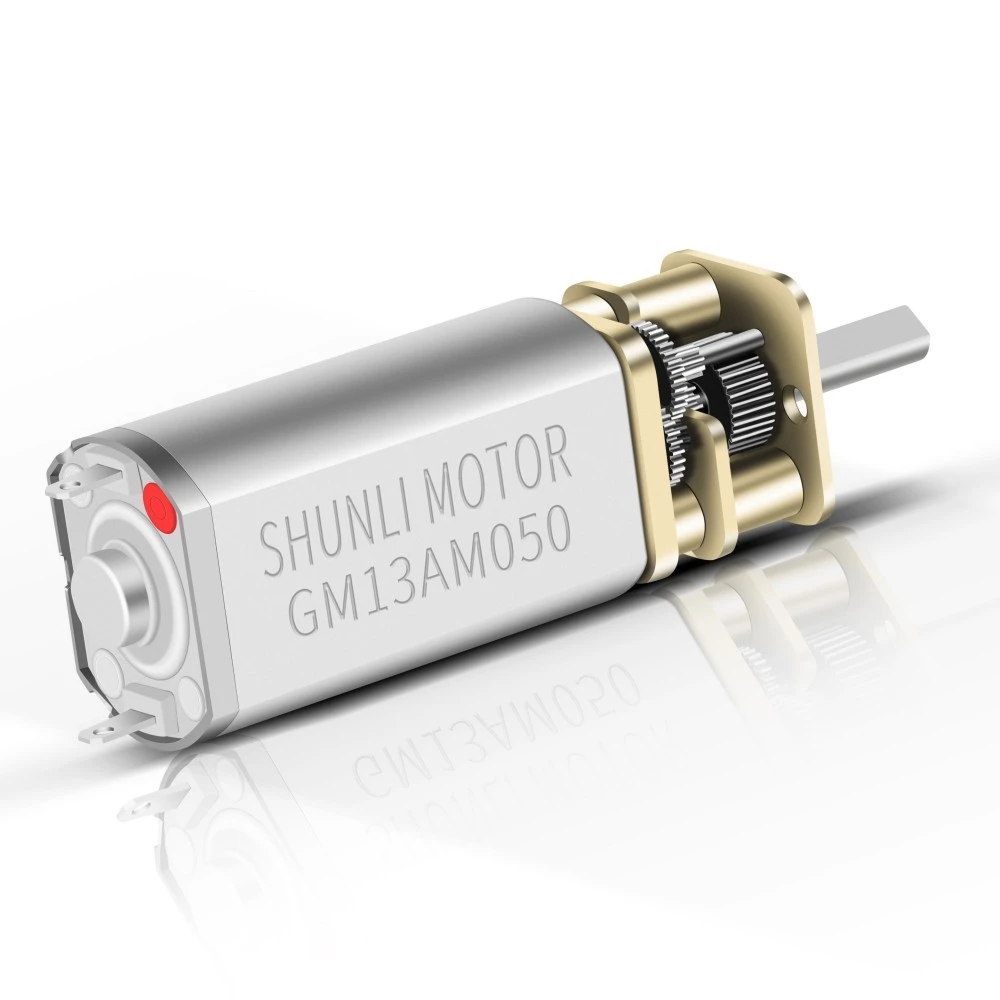
The GM13AM Series is a compact 13 mm-class DC spur gear motor designed for miniature mechanisms that require efficient speed reduction, stable low-speed output, and cost-effective transmission in a limited installation space.
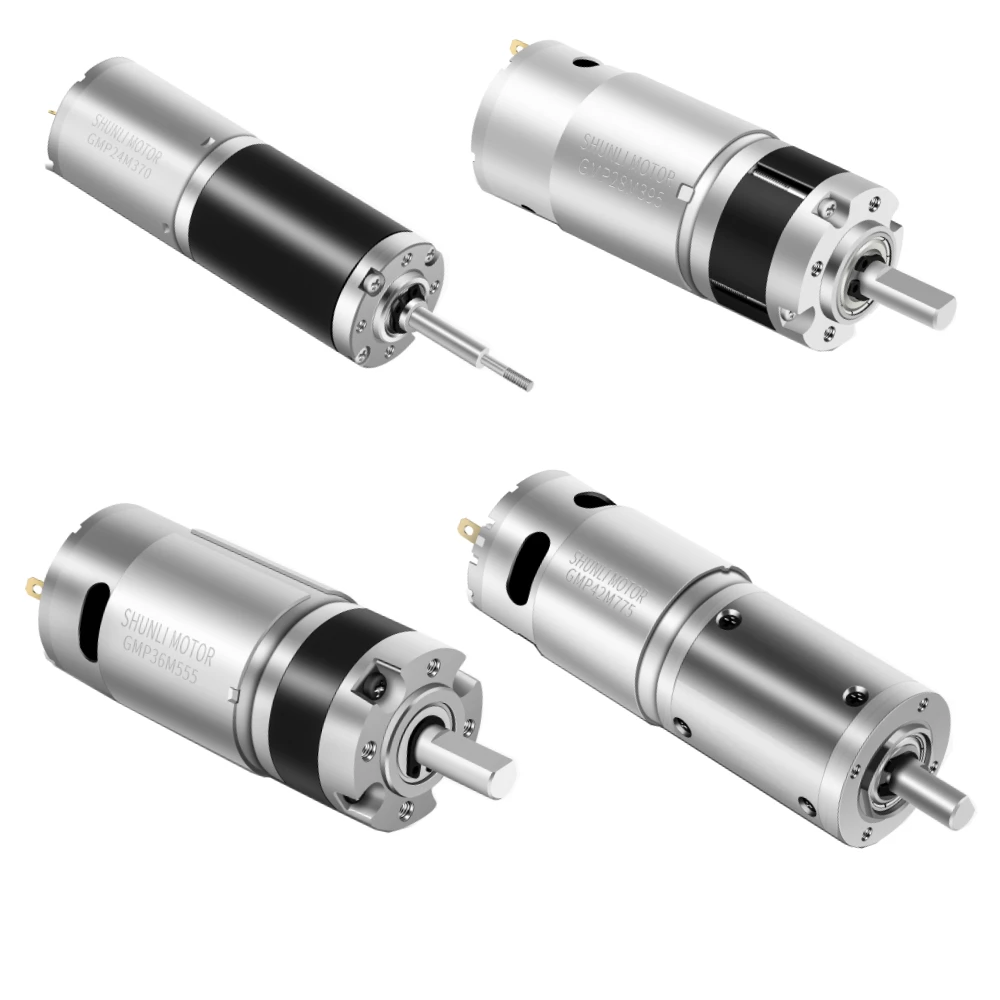
The Planetary Gear Motor uses a compact coaxial planetary gearbox to deliver higher torque density and stable transmission within limited installation space. Multiple planet gears share the load, making the structure suitable for applications that require compact size, reliable load handling, and frequent start-stop or reversing motion. It is widely used in robotics, medical equipment, industrial automation, automotive actuators, precision mechanisms, and other compact motion systems. Final selection should consider output speed, continuous and peak torque, duty cycle, backlash, current, and installation requirements.
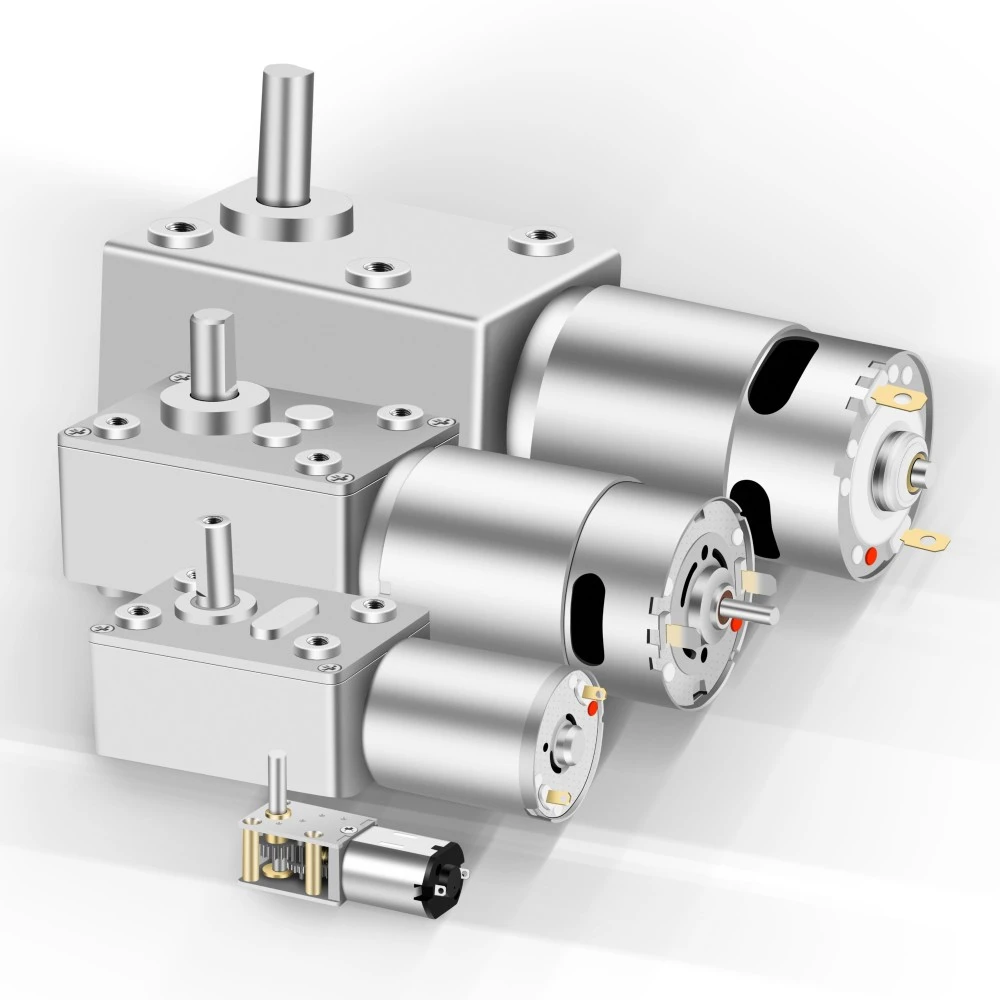
The DC Worm Gear Motor combines a DC motor with a worm gearbox to provide right-angle transmission, high reduction ratios, low-speed output, and strong load-driving capability in a compact structure. Its 90° output arrangement is well suited to valves, lifting and adjustment mechanisms, doors and windows, vending equipment, and other actuators where space layout or load-holding performance is important. Depending on the gear geometry and operating conditions, some worm gear designs may provide holding or self-locking characteristics, which should be verified for the actual application.
The GM16 Series is a compact 16 mm-class DC spur gear motor platform designed for miniature transmission systems that require efficient speed reduction, controlled low-speed output, cost-effective construction, and repeatable mass production.
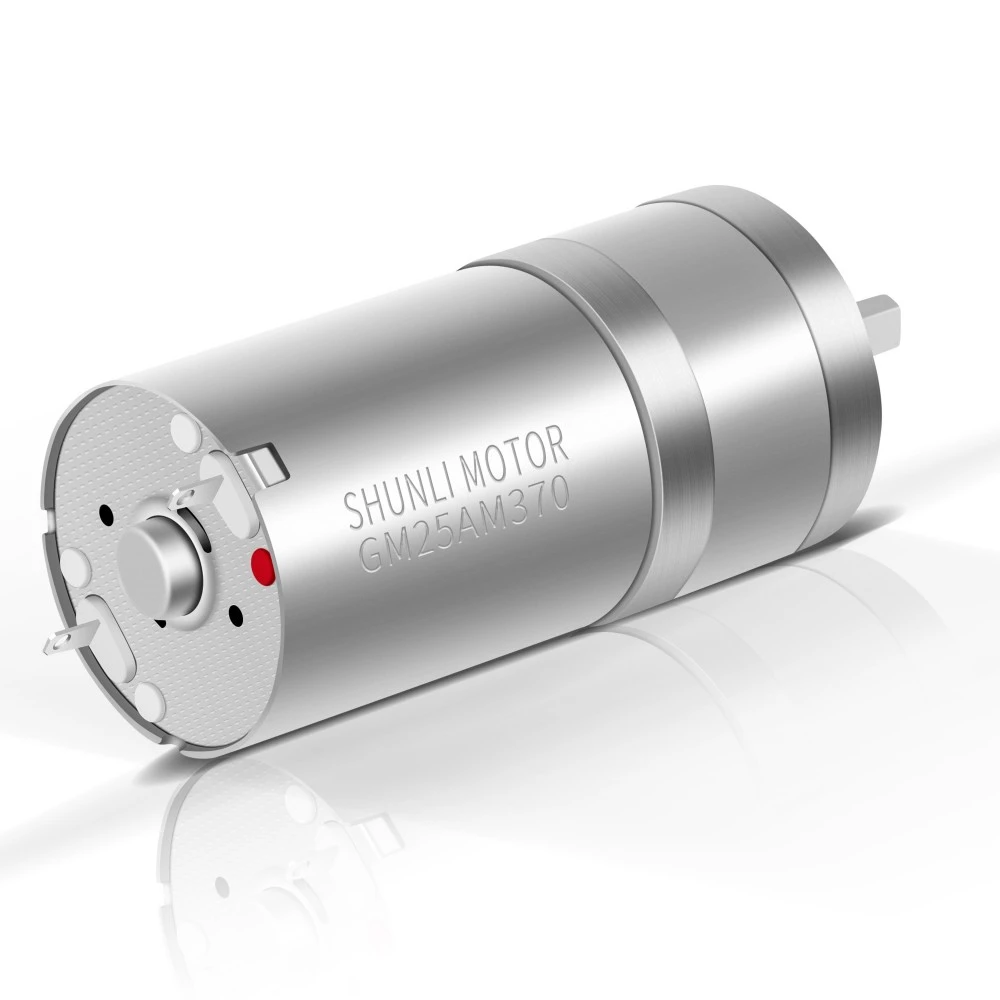
The GM25AM310/370 is a 25 mm-class DC spur gear motor platform combining a compact multi-stage gearbox with PMDC 310 or 370 motors. The supplied technical data covers gearbox options from 3 to 8 stages, multiple reduction ratios, and two reference gearmotor configurations: GM25AM310-217K at 3 VDC and GM25AM370-99K at 12 VDC.
The GM24 Series is a compact 24 mm-class DC spur gear motor platform developed for small transmission mechanisms that require efficient speed reduction, stable output, and cost-effective mass production.
Navigation
Navigation
Product Categories
Product Categories
Contact Us
Get in Touch
Get in Touch
Request a Quote
 Youtube
 Tiktok
 Linkedin
 Instagram
 Facebook
 WhatsApp
 WeChat