Why Robot Joints Cannot Use One Universal Gear Motor: A Real Micro Gear Motor Customization Project
Why Robot Joints Cannot Use One Universal Gear Motor: A Real Micro Gear Motor Customization Project
Nov. 20, 2026
How should engineers choose a micro gear motor solution for an AI robot? Start with the motion task, not the motor. Wheels need torque and impact resistance. Camera gimbals need quiet operation and repeatable positioning. Joint modules need low backlash and fast settling. Grippers must deliver the required movement where installation space is measured in millimeters.
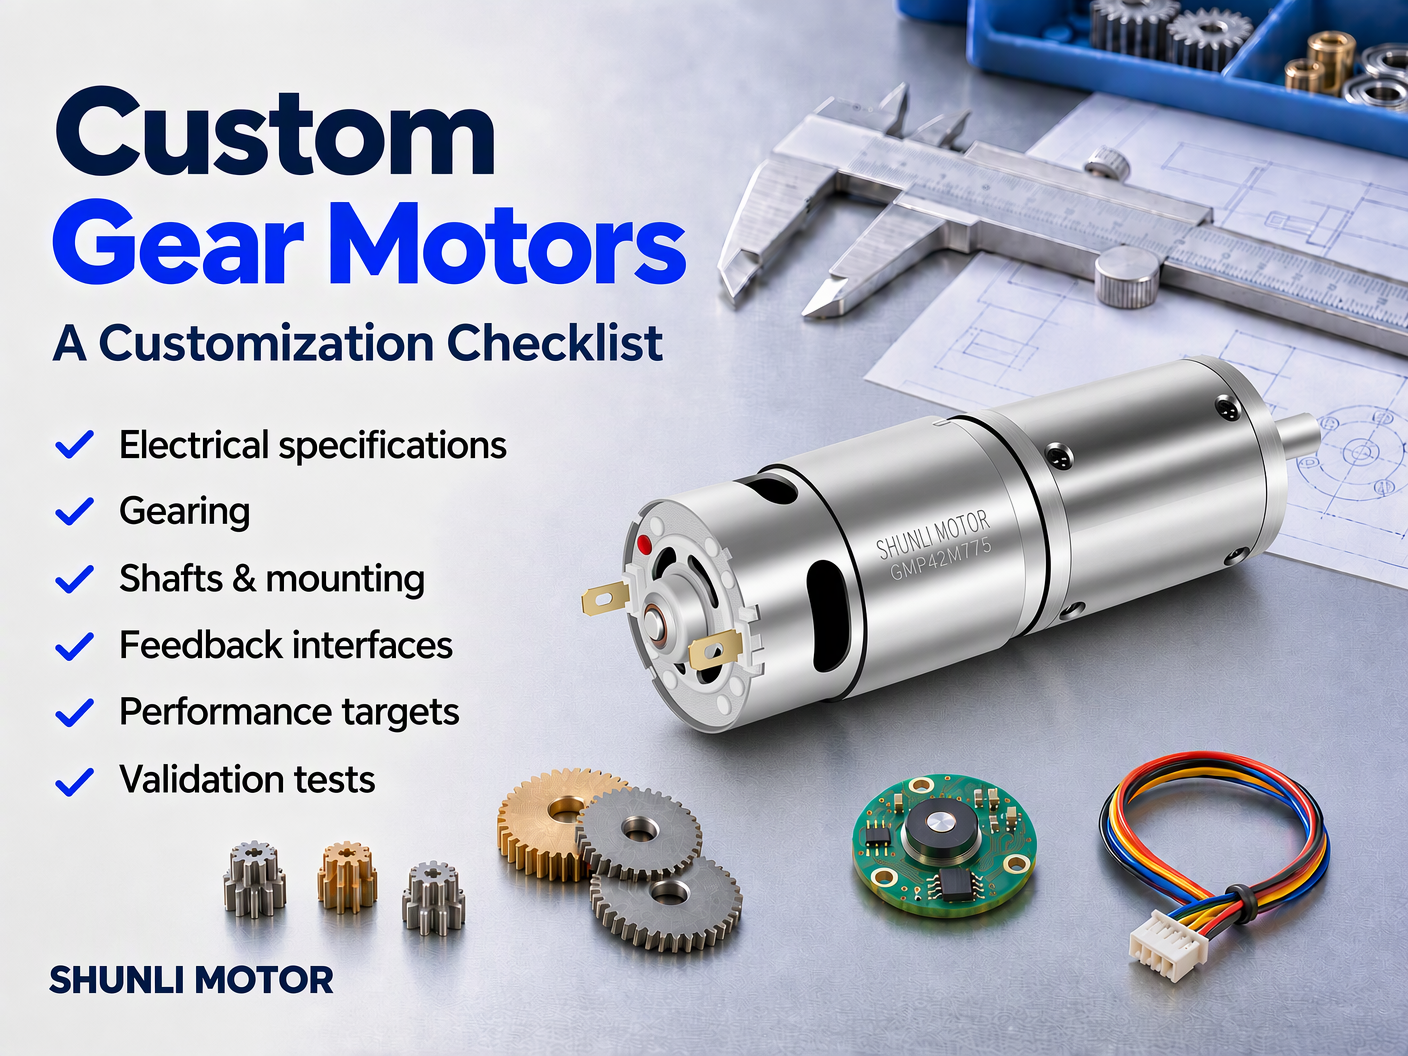
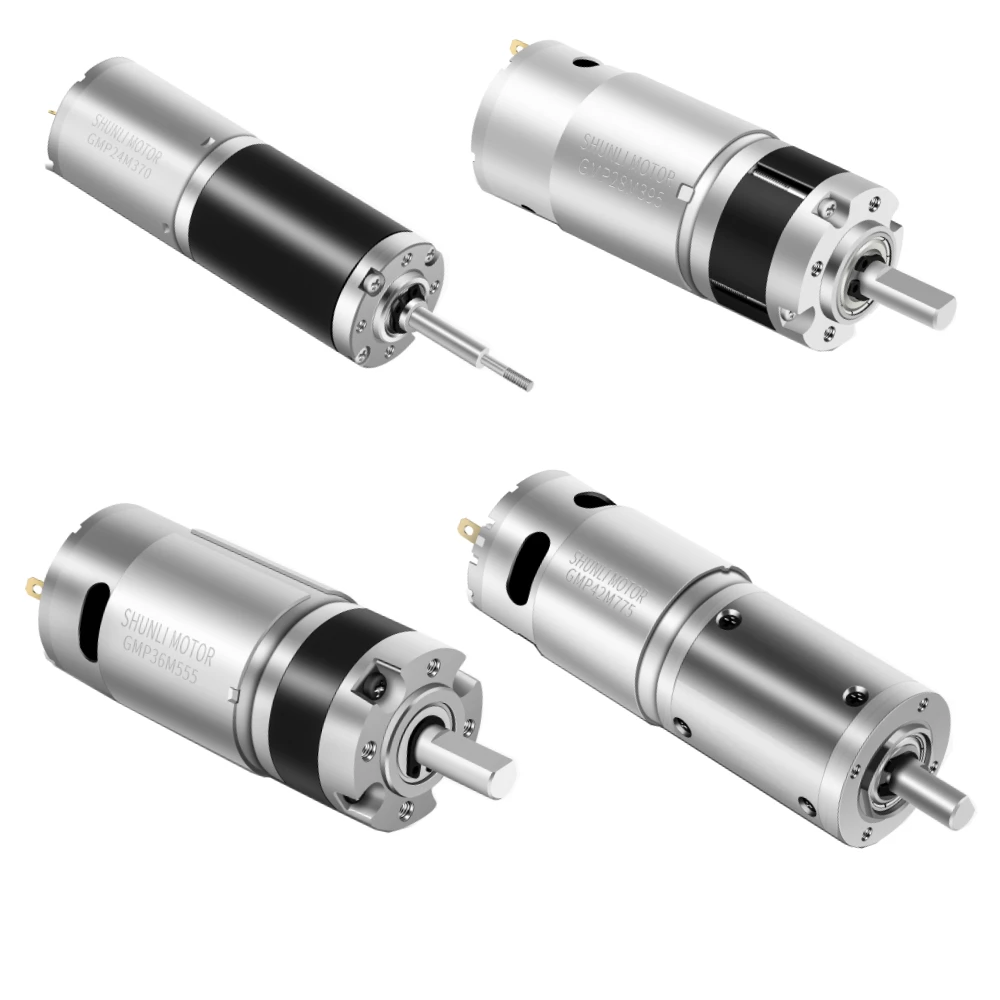
GMP36 and GMP42 planetary gear motors use 36 mm and 42 mm frames and are available with brushed or brushless motor configurations, including BL4260 and BL4266 classes. They are designed for continuous operation, curb impacts, and sudden load changes between carpet and tile.
In Zhiyuan cleaning robots, GMP36 drives the side brush. In Pudu delivery fleets, GMP42 supports the chassis. Design verification should compare continuous torque with peak torque under curb and slope conditions, and bearing life with the radial load from the wheel assembly.
The GMP24 planetary unit is used for low-mass, high-frequency positioning applications. Gear noise and positioning repeatability influence whether a robot feels precise or inexpensive to the people around it.
GMP28HP combines a coreless motor with a high-precision planetary gearbox for fast-settling joints. The 4.4 mm ultra-micro planetary gear motor, released in 2025, is intended for finger joints where the available installation space is measured in millimeters. Feedback can be provided by a magnetic encoder or Hall sensor and matched to the control loop.
The GM37 gear motor is used for the head gimbal of companion robots. It has been shipped in volume, and one important selection factor is keeping the gear train quiet enough for a living-room environment while maintaining the required movement.
1.Voltage window: 3–36 V to match the battery bus.
2.Reduction ratio and structure: Spur, planetary, or worm gearing. When the mechanism must hold its position after power is removed, a 12V worm drive motor can use self-locking geometry.
3.Output shaft: Diameter, material, flat, cross-hole, dual output shaft, and tapped shaft end.
4.Mounting: Hole pattern, flange, and threaded posts to match the customer’s structural parts.
5.Electrical interface: Lead length, connector, Hall or encoder wire count, and drive solution.
6.Performance targets: Noise limit, life cycles, backlash, temperature range, and sealing level for humid or outdoor conditions.
In a worm-drive project for a lawnmower tipping mechanism, the complete machine weighed 420 grams. The customized solution used a tin-bronze worm gear, a PEEK worm wheel rated for 250°C, and a zinc-alloy die-cast housing. The lead angle provided mechanical self-locking so that the mechanism would not drop when power was removed.
Robots need low noise when they work close to people, but they also need hardened gears to withstand impact. A workable compromise, demonstrated in the lawnmower project by reducing gearbox noise from 65 dB(A) to 52 dB(A), is staged transmission.
The high-speed, noise-sensitive stage uses PEEK helical gears. The high-torque planetary stage uses carburized and ground 40CrMnTi steel gears with a hardness of HRC 50–55. Gear accuracy, preload, and assembly tolerances reduce backlash. The final few arc minutes can be compensated on the control side after the encoder is integrated into the closed loop.
The process begins with a requirement review covering duty cycle, load, speed, available space, voltage, and environment. One mechanism drawing or a prototype can be enough to start the discussion. The process then continues through solution design, samples, small-batch trial production, and mass production.
Gear design, tooling, machining, injection molding, assembly, and testing are carried out within one 10,800-square-meter factory. The engineer who designs the tooth profile can observe the first gear being cut and the first life test. Engineering changes are revalidated before shipment, and the golden sample anchors subsequent production batches. The factory has an annual production capacity above 20 million units and operates under the discipline of ISO 13485 and IATF 16949.
Contact shunlimotor@szslmotor.com with the application requirements.
Yes. Send the end product, a mechanism drawing, or a prototype, and the engineering team can help break down the motion task. A formal quotation requires confirmation of load, speed, available space, and duty cycle.
Options include Hall sensors, magnetic encoders, optical encoders, dual output shafts, and drive interfaces. Resolution and signal format are determined together with the customer’s control engineers.
Yes. Drive units have been used in volume applications for service, delivery, and cleaning robots from Pudu Robotics and Zhiyuan Robot. Additional companion-robot, lawnmower-robot, and pool-cleaning-robot projects are distributed across Europe, North America, and Asia.
Product Categories
Enable Customized Solutions to Be Implemented Faster
Whether you're in the product concept, prototype development, or mass production phase, Shunli Motors can help you find the right micro geared motor drive solution based on your specific application needs.
Submit your product requirements now and get selection advice from our engineers.
Related Products
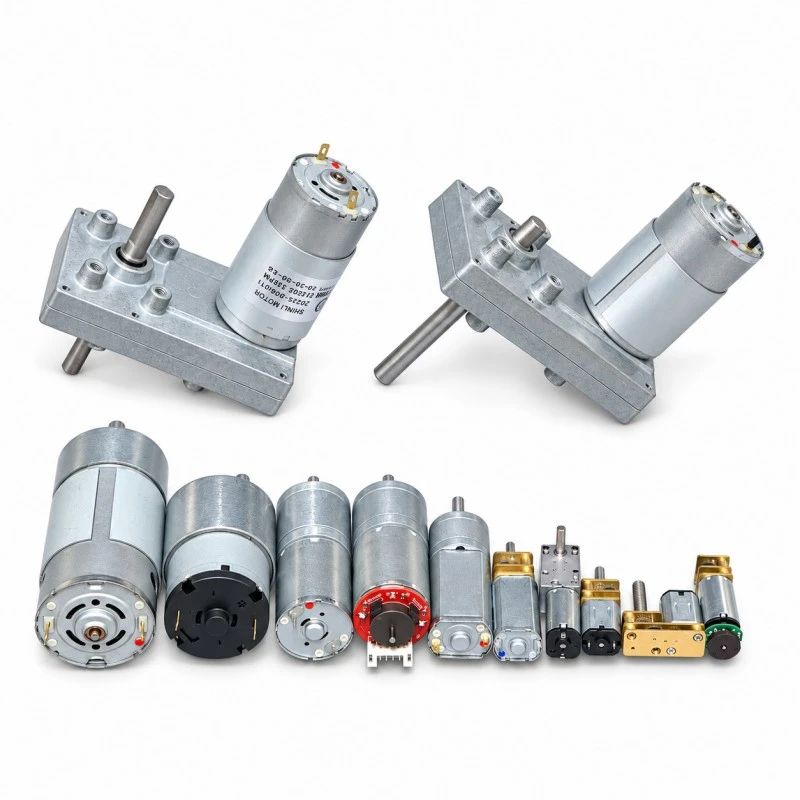
The Spur Gear Motor combines a DC motor with a multi-stage spur gearbox to provide a mature, efficient, and cost-effective drive solution for compact transmission mechanisms. Its simple gear structure supports flexible ratio, shaft, and mounting customization, making it suitable for smart home devices, commercial equipment, automotive actuators, smart landscaping systems, and industrial automation. It is a practical choice for projects that need a balance of output speed, torque, reliability, manufacturability, and cost.
The Planetary Gear Motor uses a compact coaxial planetary gearbox to deliver higher torque density and stable transmission within limited installation space. Multiple planet gears share the load, making the structure suitable for applications that require compact size, reliable load handling, and frequent start-stop or reversing motion. It is widely used in robotics, medical equipment, industrial automation, automotive actuators, precision mechanisms, and other compact motion systems. Final selection should consider output speed, continuous and peak torque, duty cycle, backlash, current, and installation requirements.
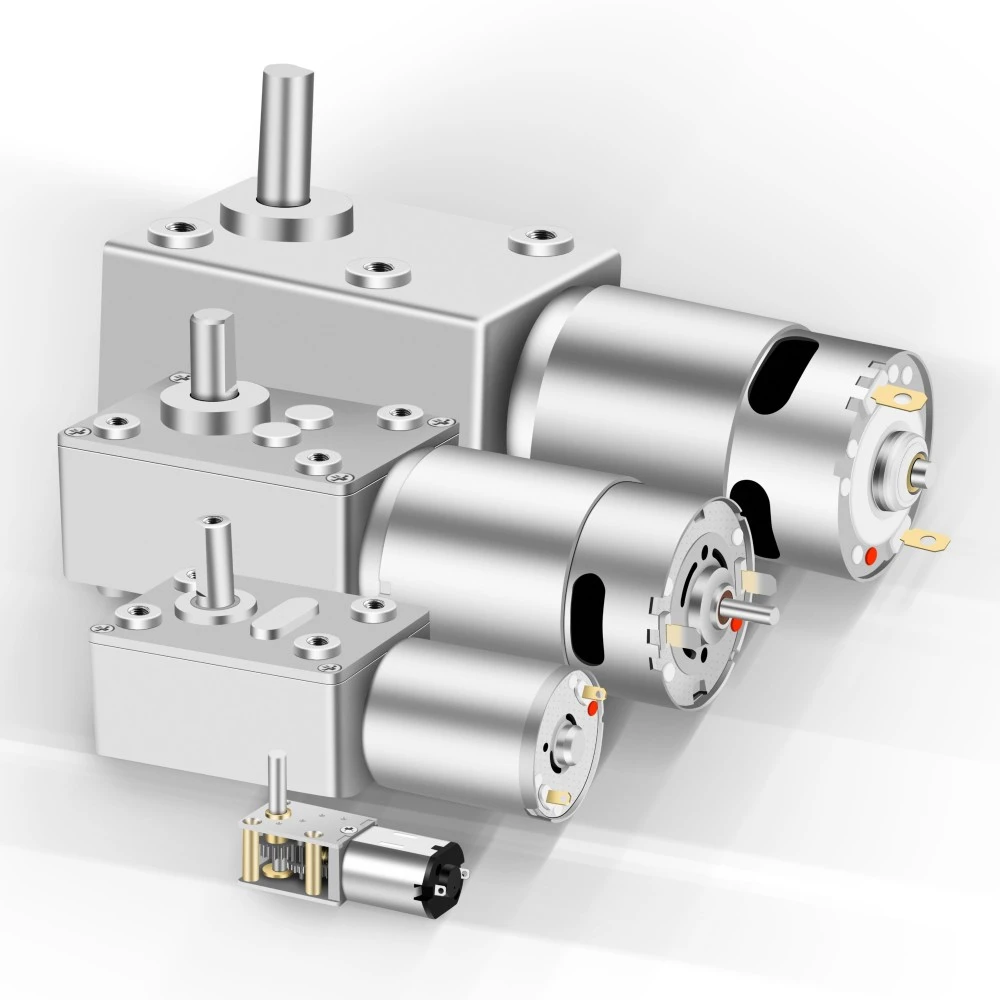
The DC Worm Gear Motor combines a DC motor with a worm gearbox to provide right-angle transmission, high reduction ratios, low-speed output, and strong load-driving capability in a compact structure. Its 90° output arrangement is well suited to valves, lifting and adjustment mechanisms, doors and windows, vending equipment, and other actuators where space layout or load-holding performance is important. Depending on the gear geometry and operating conditions, some worm gear designs may provide holding or self-locking characteristics, which should be verified for the actual application.
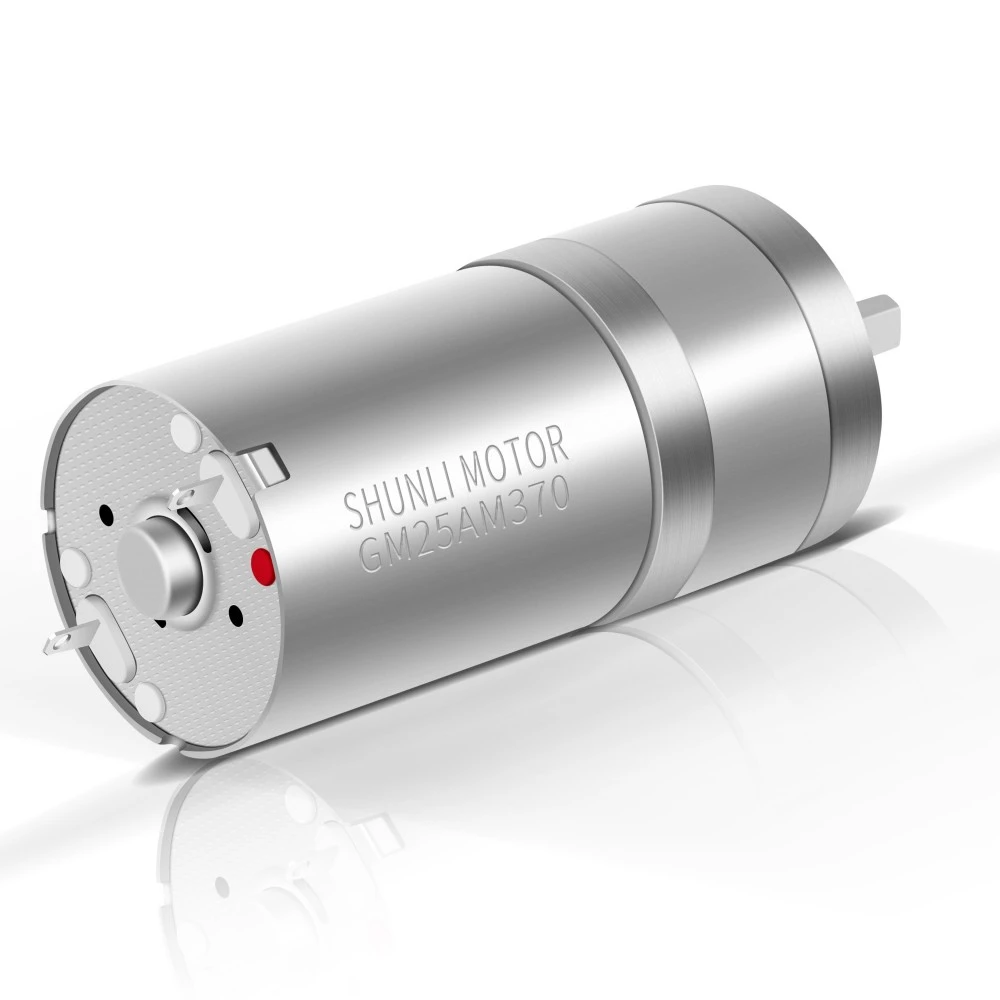
The GM25AM310/370 is a 25 mm-class DC spur gear motor platform combining a compact multi-stage gearbox with PMDC 310 or 370 motors. The supplied technical data covers gearbox options from 3 to 8 stages, multiple reduction ratios, and two reference gearmotor configurations: GM25AM310-217K at 3 VDC and GM25AM370-99K at 12 VDC.
Navigation
Navigation
Product Categories
Product Categories
Contact Us
Get in Touch
Get in Touch
Request a Quote
 Youtube
 Tiktok
 Linkedin
 Instagram
 Facebook
 WhatsApp
 WeChat