Brushless Planetary Gear Motor GMP36MBL3626
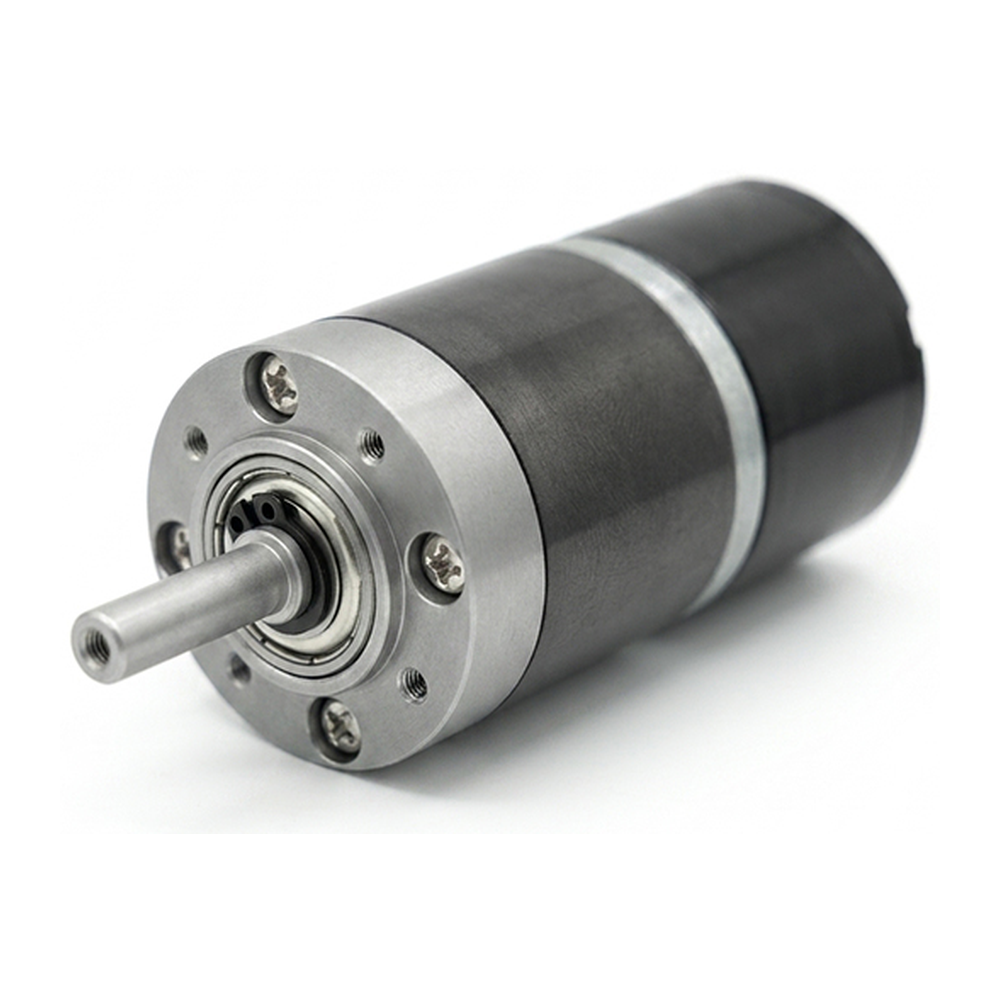
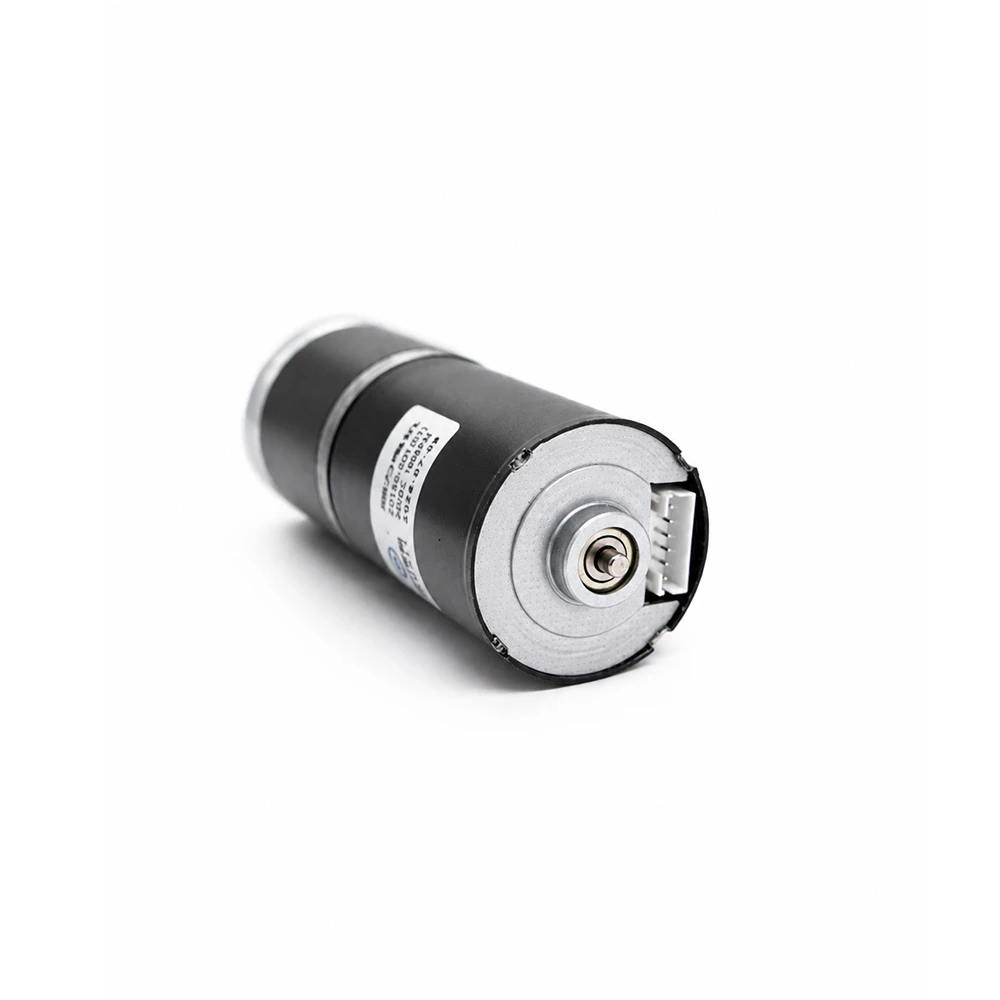
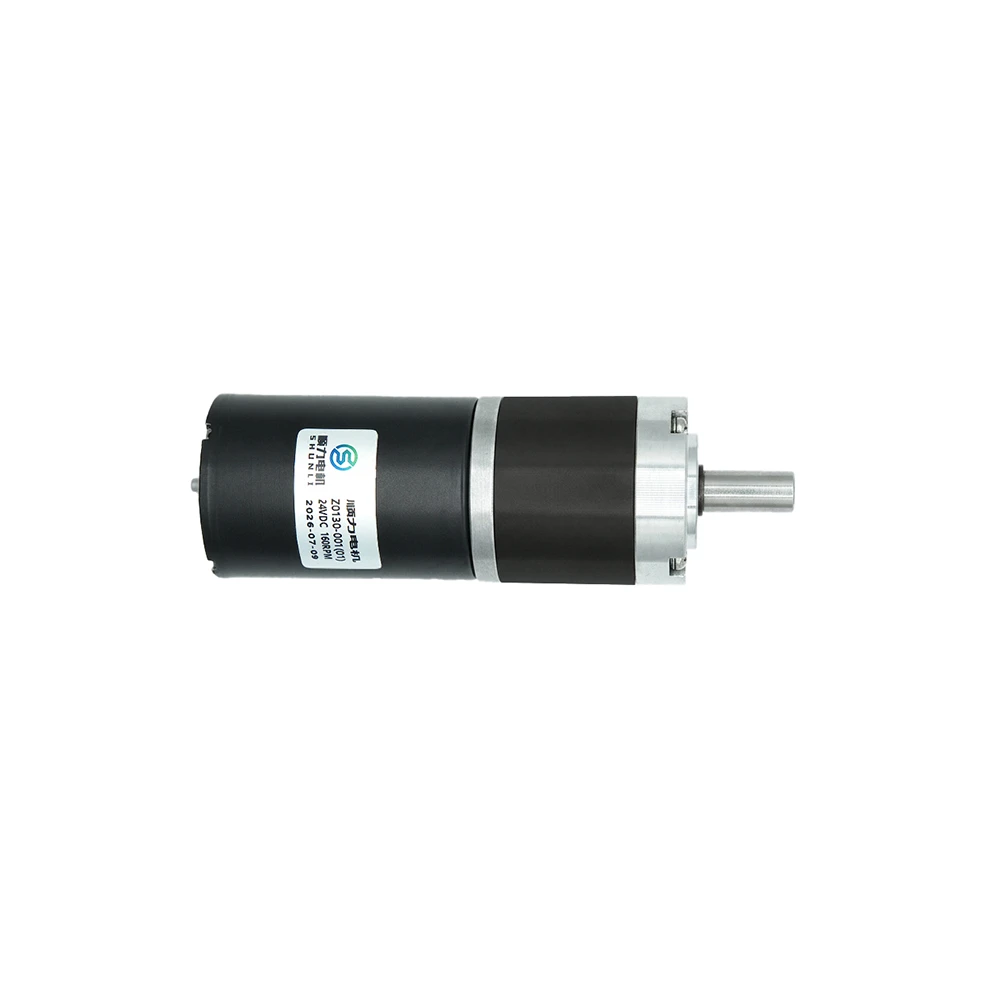
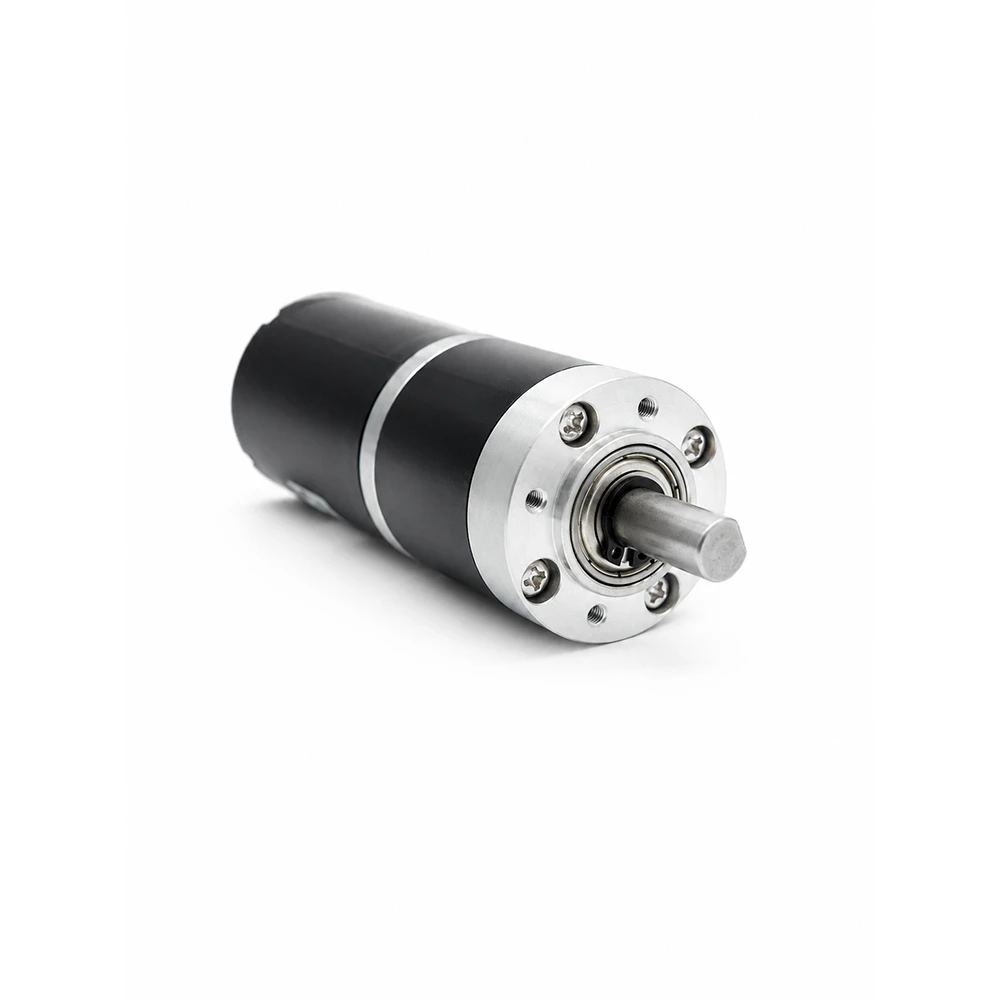
The GMP36MBL3626 brushless planetary gear motor is a compact 24V DC drive solution combining a GMP36-51K planetary gearbox with a BL3650 brushless DC motor. The supplied engineering drawing specifies a 1:51 reduction ratio, 160 ±10% RPM free-load output speed, 125 ±10% RPM rated output speed, and 14 kgf·cm reference rated torque.
Product Overview
The GMP36MBL3626 brushless planetary gear motor is a compact 24V DC drive solution combining a GMP36-51K planetary gearbox with a BL3650 brushless DC motor. The supplied engineering drawing specifies a 1:51 reduction ratio, 160 ±10% RPM free-load output speed, 125 ±10% RPM rated output speed, and 14 kgf·cm reference rated torque. Minimum stall torque is 60 kgf·cm. With an integrated six-wire control interface for VCC, FG speed feedback, CW/CCW direction control, GND, PWM speed regulation, and brake control, this 36 mm-class BLDC planetary gear motor is designed for OEM applications requiring compact size, high torque density, controlled speed, and long-cycle brushless operation. Typical uses include smart actuators, robotics, automation equipment, dispensing mechanisms, medical or laboratory equipment, and other precision electromechanical systems.
Model Information
| Item | Specification |
| Project / Customer Code | GMP36MBL3626 |
| Product Series | GMP36-51K |
| Motor Type | Brushless DC Motor |
| Product Type | Brushless Planetary Gear Motor |
| Driving Motor | BL3650# |
| Rated Voltage | 24 VDC |
| Reference Gear Ratio | 1:51 |
| Driver / Control | 6-wire BLDC control interface with PWM, FG and brake |
Main Parameters
| Parameter | Specification |
| Rated Voltage | 24 VDC |
| Gear Ratio | 1:51 |
| Free-load Speed | 160 ±10% RPM |
| Free-load Current | 300 mA Max |
| Rated Speed | 125 ±10% RPM |
| Rated Current | 1500 mA Max |
| Rated Torque | 14 kgf·cm REF (≈1.37 N·m) |
| Stall Current | 7500 mA Max |
| Stall Torque | 60 kgf·cm Min (≈5.88 N·m) |
| Stall Allowed | No |
| Direction | CW / CCW |
| Noise | 62 dB Max at L=300 mm |
| Driving Motor Model | BL3650# |
| Driving Motor Free-load Speed | 8000 ±10% RPM |
| Driving Motor Free-load Current | 200 mA Max |
Reference Output Performance
| Voltage | Ratio | No-load Speed | No-load Current | Rated Speed | Rated Current | Rated Torque | Stall Current | Stall Torque |
| 24 VDC | 1:51 | 160 RPM | 300 mA Max | 125 RPM | 1500 mA Max | 14 kgf·cm REF | 7500 mA Max | 60 kgf·cm Min |
Motor Control & Feedback
| Control Item | Specification |
| VCC | Pin 1 / Red |
| FG Feedback | Pin 2 / Yellow |
| Direction Control | Pin 3 / White, CW/CCW |
| GND | Pin 4 / Black |
| PWM Input | Pin 5 / Blue, 10 kHz-20 kHz noted on drawing |
| Brake | Pin 6 / Green |
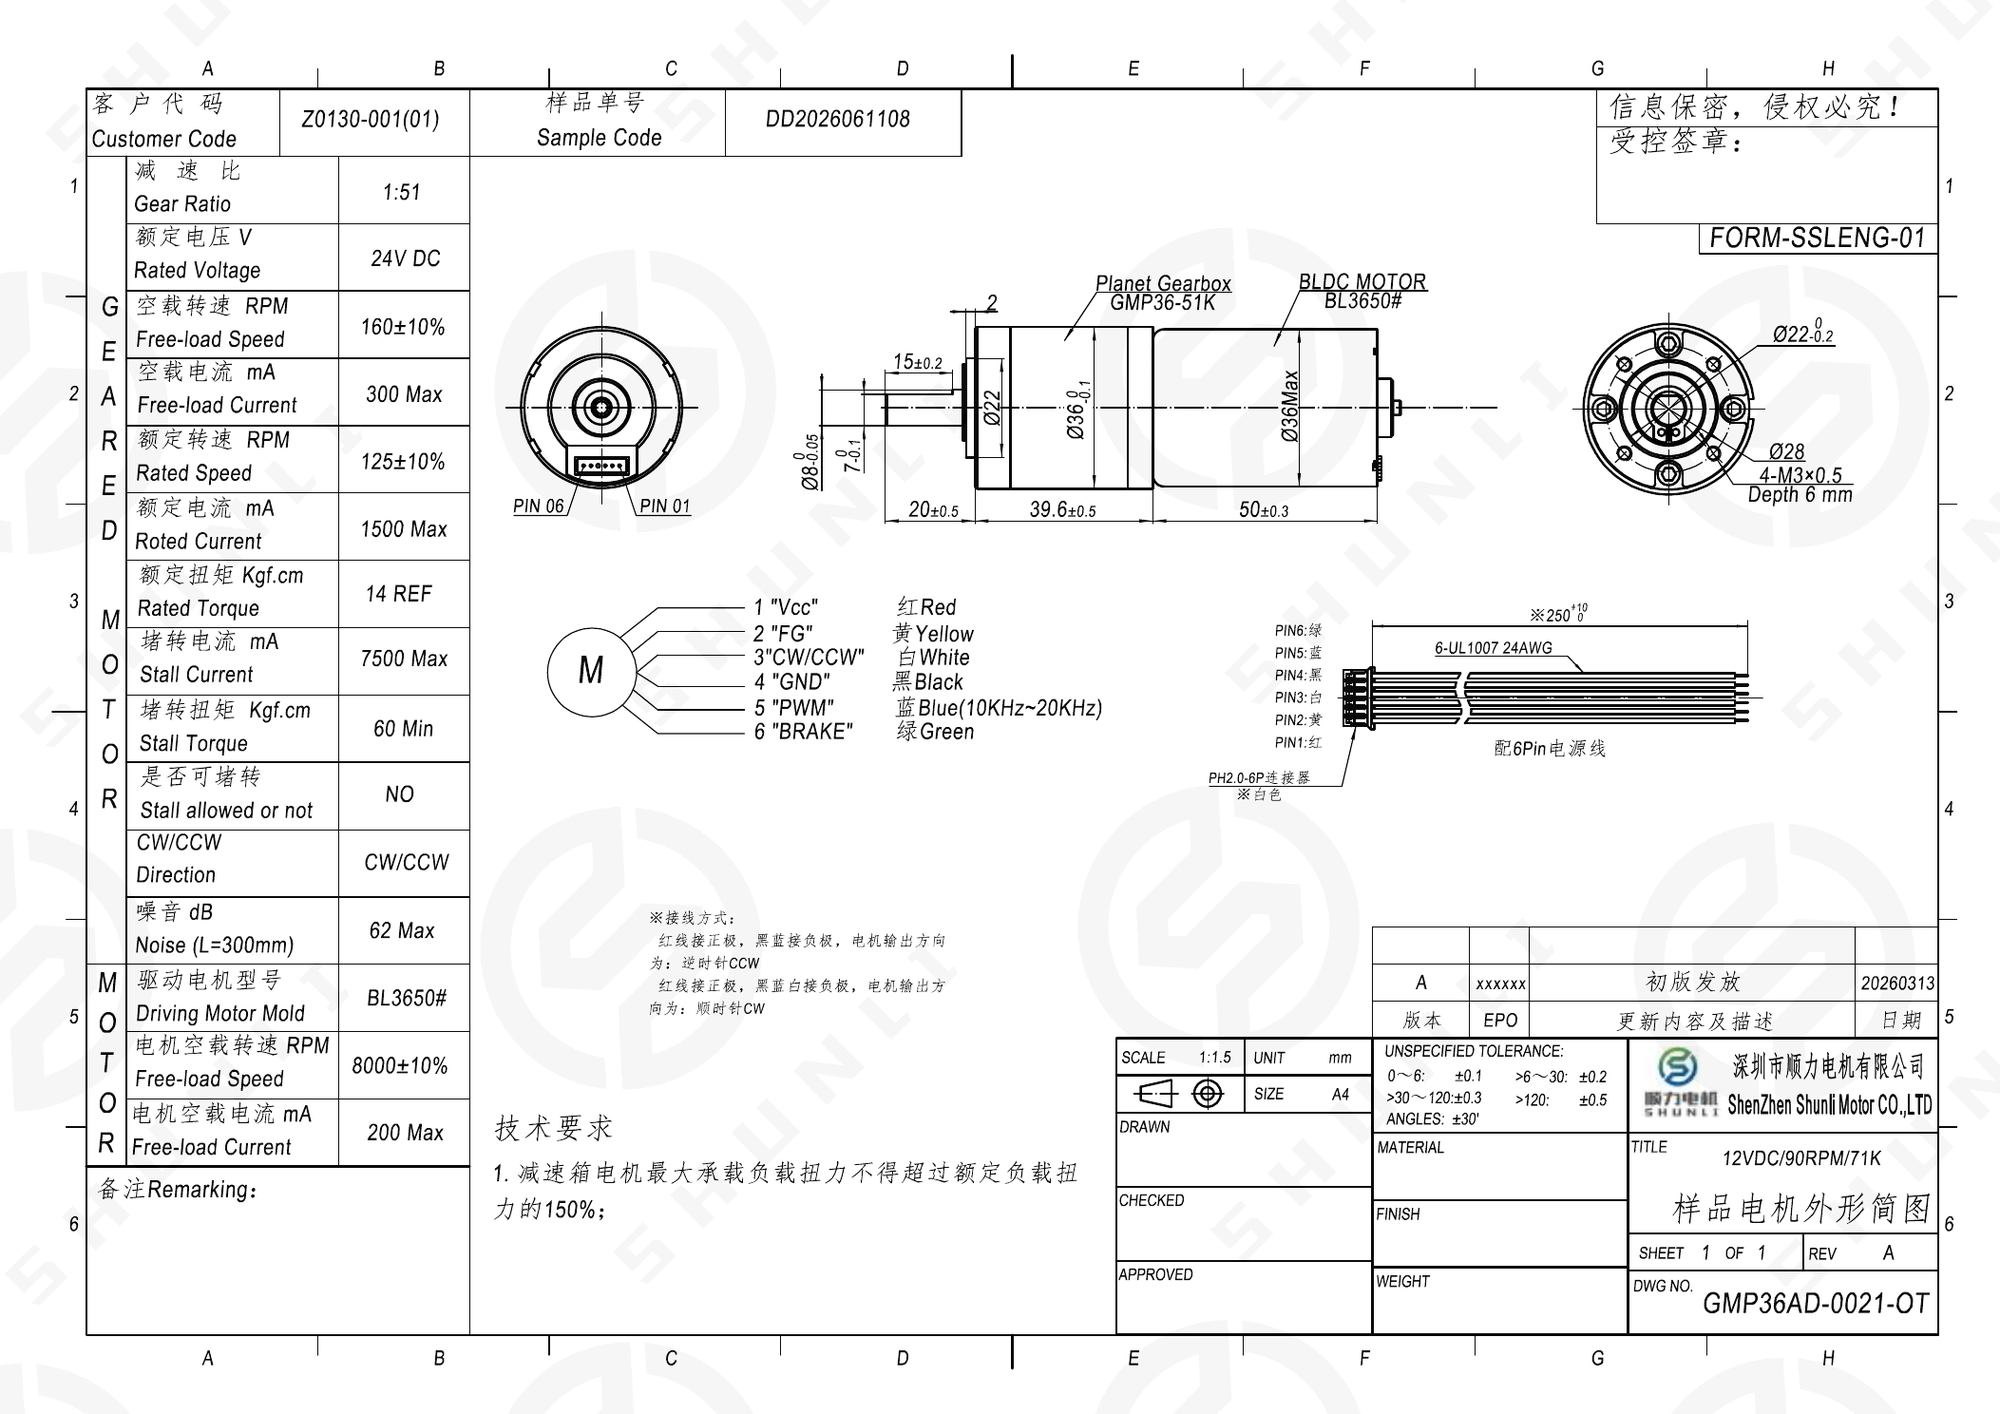
| Harness | 6 × UL1007 24AWG, approx. 250 mm |
| Connector | PH2.0-6P, white |
Mechanical Specifications
| Mechanical Item | Specification |
| Gearbox Type | Planetary Gearbox GMP36-51K |
| Gearbox Outside Diameter | Ø36.8 mm class |
| Motor Outside Diameter | Ø36 mm Max |
| Gearbox Length | 39.6 ±0.5 mm |
| Motor Length | 50 ±0.3 mm |
| Front Pilot Diameter | Ø22 mm |
| Mounting Circle | Ø28 mm |
| Mounting Threads | 4 × M3 × 0.5, depth 6 mm |
| Output Shaft Extension | 15 ±0.2 mm from front reference |
| Harness Length | Approx. 250 mm |
Dimension Drawing
Engineering Advantages
• 24V brushless motor platform supports lower maintenance and longer service life than brushed motor solutions.
• Planetary reduction structure provides high torque density in a compact 36 mm-class package.
• 1:51 reference ratio provides controlled low-speed output for actuator and transmission mechanisms.
• FG feedback, PWM input, CW/CCW direction control, and brake signal support closed-loop or system-level motion control.
• 14 kgf·cm reference rated torque and 60 kgf·cm minimum stall torque provide useful torque reserve for compact drive applications.
• Metal gearbox structure and multi-point mounting interface support stable OEM integration.
Main Applications
Robotics and intelligent actuator modules
Industrial automation and compact positioning mechanisms
Smart equipment, valves, latches, and opening/closing mechanisms
Dispensing, vending, and commercial equipment drive modules
Medical, laboratory, and analytical equipment subassemblies
Other OEM devices requiring a compact 24V brushless planetary gear motor with feedback and PWM control
Customization Range
Electrical Configuration
Rated voltage and winding specification
Motor speed and target output speed
PWM, FG, brake, and direction-control logic
Connector and wire definition
Gearbox & Performance
Gear ratio selection
Target output speed and torque
Backlash and noise requirements
Duty cycle and service-life target
Mechanical Interface
Output shaft diameter, flat, thread, or special machining
Mounting interface and pilot geometry
Harness length and connector type
Cable outlet orientation
Reliability Validation
Operating temperature and environmental conditions
Load spectrum, start/stop frequency, and peak load
Noise/vibration requirements
Life-cycle and batch-consistency validation
Information Required for Custom Evaluation
Target output speed, rated torque, and peak/stall condition
Input voltage and controller interface requirements
Installation space, mounting drawing, and output shaft specification
Duty cycle, daily cycle count, and expected lifetime
Noise, temperature, and environmental requirements
Annual quantity and validation/certification requirements
FAQ
Q1. What are the main specifications of the GMP36MBL3626 brushless planetary gear motor?
The supplied reference configuration is 24 VDC with a 1:51 planetary reduction ratio, 160 RPM free-load speed, 125 RPM rated speed, 14 kgf·cm reference rated torque, and 60 kgf·cm minimum stall torque.
Q2. Does this BLDC planetary gear motor support speed and direction control?
Yes. The drawing provides PWM input, FG speed feedback, CW/CCW direction control, and a brake signal through a six-wire control interface.
Q3. What is the gearbox and motor size?
The design uses a GMP36-51K planetary gearbox with an approximately Ø36.8 mm gearbox body and a BL3650 motor with Ø36 mm maximum diameter.
Q4. Can the output shaft, gear ratio, cable, and connector be customized?
Yes. These items can be reviewed according to the customer installation drawing, target speed, torque, control interface, and annual quantity.
Q5. Is stall operation allowed?
No. The supplied drawing marks stall operation as not allowed. System-level current limiting, timeout protection, or brake/control logic should be used to avoid prolonged stall conditions.
Q6. What information is needed for OEM selection?
Please provide voltage, target speed, rated and peak torque, installation space, shaft and mounting drawing, duty cycle, control-signal requirements, operating environment, and target lifetime.
Product Categories
Enable Customized Solutions to Be Implemented Faster
Whether you're in the product concept, prototype development, or mass production phase, Shunli Motors can help you find the right micro geared motor drive solution based on your specific application needs.
Submit your product requirements now and get selection advice from our engineers.
Related Products
The Spur Gear Motor combines a DC motor with a multi-stage spur gearbox to provide a mature, efficient, and cost-effective drive solution for compact transmission mechanisms. Its simple gear structure supports flexible ratio, shaft, and mounting customization, making it suitable for smart home devices, commercial equipment, automotive actuators, smart landscaping systems, and industrial automation. It is a practical choice for projects that need a balance of output speed, torque, reliability, manufacturability, and cost.
The GM12 Series is a compact 12 mm-class DC spur gear motor platform developed for miniature mechanisms that require efficient speed reduction, controlled output, and cost-effective integration in limited space.
The GM13AM Series is a compact 13 mm-class DC spur gear motor designed for miniature mechanisms that require efficient speed reduction, stable low-speed output, and cost-effective transmission in a limited installation space.
The Planetary Gear Motor uses a compact coaxial planetary gearbox to deliver higher torque density and stable transmission within limited installation space. Multiple planet gears share the load, making the structure suitable for applications that require compact size, reliable load handling, and frequent start-stop or reversing motion. It is widely used in robotics, medical equipment, industrial automation, automotive actuators, precision mechanisms, and other compact motion systems. Final selection should consider output speed, continuous and peak torque, duty cycle, backlash, current, and installation requirements.
The DC Worm Gear Motor combines a DC motor with a worm gearbox to provide right-angle transmission, high reduction ratios, low-speed output, and strong load-driving capability in a compact structure. Its 90° output arrangement is well suited to valves, lifting and adjustment mechanisms, doors and windows, vending equipment, and other actuators where space layout or load-holding performance is important. Depending on the gear geometry and operating conditions, some worm gear designs may provide holding or self-locking characteristics, which should be verified for the actual application.
The GM16 Series is a compact 16 mm-class DC spur gear motor platform designed for miniature transmission systems that require efficient speed reduction, controlled low-speed output, cost-effective construction, and repeatable mass production.
The GM25AM310/370 is a 25 mm-class DC spur gear motor platform combining a compact multi-stage gearbox with PMDC 310 or 370 motors. The supplied technical data covers gearbox options from 3 to 8 stages, multiple reduction ratios, and two reference gearmotor configurations: GM25AM310-217K at 3 VDC and GM25AM370-99K at 12 VDC.
The GM24 Series is a compact 24 mm-class DC spur gear motor platform developed for small transmission mechanisms that require efficient speed reduction, stable output, and cost-effective mass production.
Navigation
Navigation
Product Categories
Product Categories
Contact Us
Get in Touch
Get in Touch
Request a Quote
 Youtube
 Tiktok
 Linkedin
 Instagram
 Facebook
 WhatsApp
 WeChat